01 — CAPTURE
Learn from demonstrations.
Use human examples to define a skill. Our initial focus is manipulation: turning demonstrations into policies that can reproduce useful behavior.
ROBOT LEARNING. REAL-WORLD AMBITION.
Robots should learn useful skills from experience, and keep building on what they know.
We’re building toward reusable robot skills — learned from demonstrations, adapted through experience, and evaluated with safety in mind.
Start with human demonstrations. Capture the task, the motion, and what success looks like.
01 / THE APPROACH
Robot behavior is still too often engineered one task at a time. Our focus is a learning workflow that makes demonstrations useful, skills reusable, and evaluation repeatable.
Use human examples to define a skill. Our initial focus is manipulation: turning demonstrations into policies that can reproduce useful behavior.
Explore how robots can acquire new tasks while retaining earlier skills. Continual learning is central to our long-term direction.
Evaluate learned behavior against task objectives, physical constraints, and failure cases before considering hardware deployment.
PRODUCT DIRECTION
A robot-learning workspace for robotics teams and research labs: organize demonstrations, develop manipulation skills, and compare policy behavior across tasks.
02 / THE INTELLIGENCE LAYER
Language models can help make a robotics workflow more useful, from describing a task to understanding why a trial failed.
Planned integration with the Claude API
Use Claude to help translate natural-language instructions into structured task descriptions and evaluation criteria.
Explore Claude-assisted interpretation of rollout logs, failure cases, and policy comparisons to guide the next experiment.
Build a conversational layer for navigating experiments and documenting results, alongside the underlying learning tools.
The planned architecture keeps language-model reasoning at the task and analysis level. Learned policies and dedicated controllers handle robot motion.
03 / RESEARCH FOUNDATIONS
Selected projects from the founder’s academic research at TUM. These experiments inform our approach to learning, high-level reasoning, and real-hardware integration.
 REAL-HARDWARE RESEARCH
REINFORCEMENT LEARNING / CONTROL
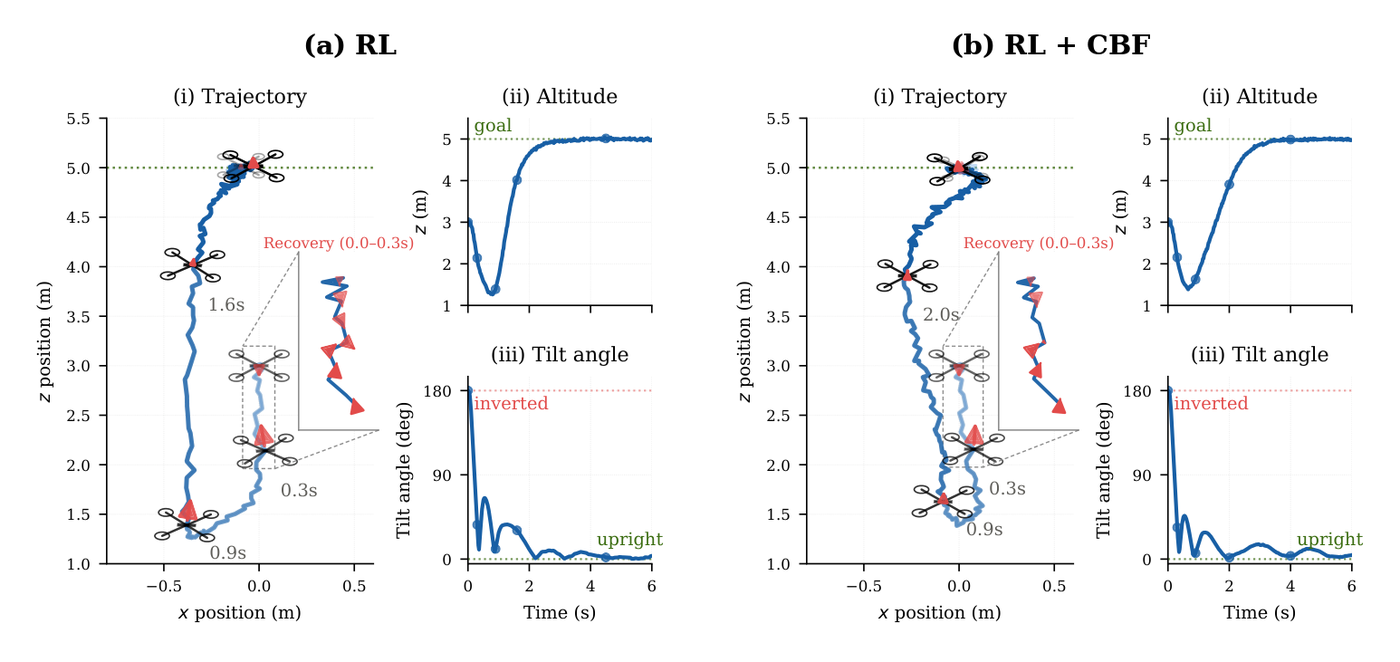
A learned quadrotor recovery policy with a Control Barrier Function filter, deployed on an Agilicious drone.
Explore the researchFOUNDATION MODELS / ROBOTICS
A ROS 2 driving stack combining language and vision models with classical control and a safety state machine.
Explore the research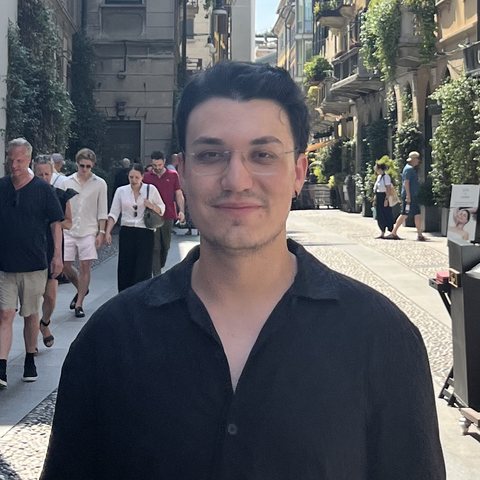
04 / THE FOUNDER
I’m Oguzhan Esen, a robot learning and control engineer based in Munich. Esen Robotics is the venture I’m building around a question: how can robots keep learning useful skills?
My background combines robot-learning research at the Technical University of Munich with more than four years of industrial control engineering at AVL. My work spans safe reinforcement learning, generative policies, continual learning, and real-hardware integration.
Esen Robotics is a founder-led, early-stage venture hosted at oguzhanesen.com. This domain is our home on the web and the domain for our business email.
LET’S BUILD THE NEXT CAPABILITY.
We’d like to hear from robotics teams, research labs, and potential collaborators. Tell us about your task, your platform, and where you’re getting stuck.